A team of roboticists has developed a training approach that dramatically accelerates how mobile manipulators learn new skills in physical environments, potentially opening doors to faster deployment of autonomous systems in warehouses, hospitals, and other real-world settings.
The breakthrough, published on arXiv by researchers including Zhefei Gong and Jiachen Li, introduces HiRe-MoMa, a framework designed to overcome a persistent challenge in robotics: teaching wheeled arms to perform manipulation tasks without requiring prohibitive amounts of human demonstration or trial-and-error learning. According to arXiv, the system achieves meaningful performance improvements with approximately 30 minutes of interactive training on actual robots, a significant reduction compared to traditional approaches.
Breaking Down the Hierarchical Approach
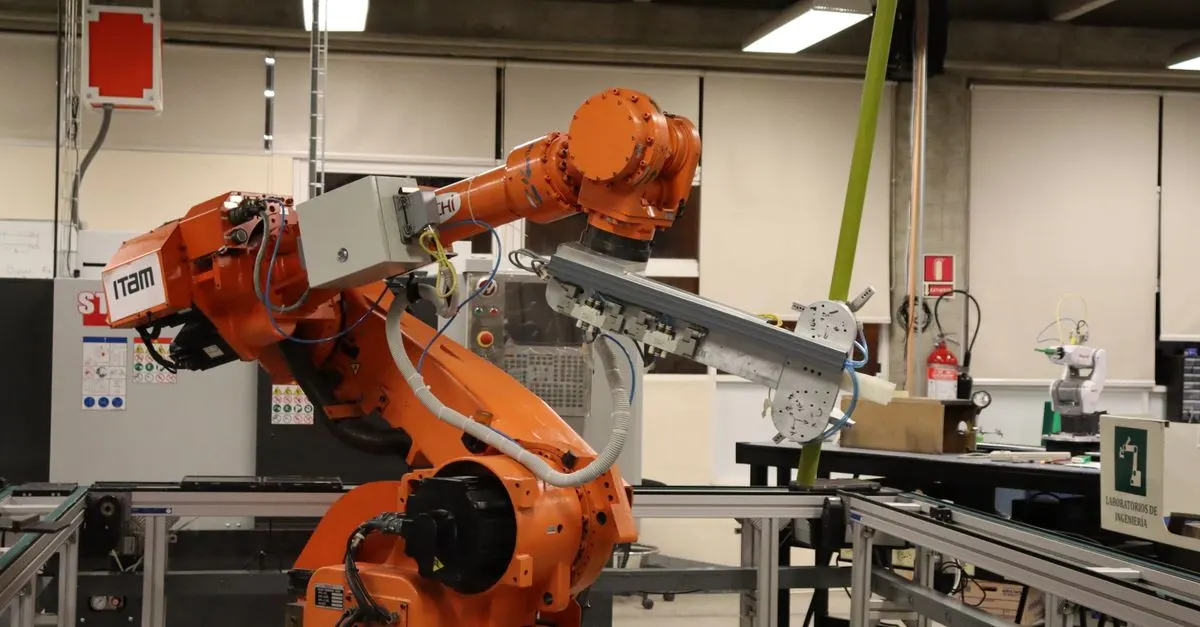
What makes HiRe-MoMa distinctive is its handling of the inherent complexity in mobile manipulation systems. These robots combine two very different mechanical subsystems: a mobile base for navigation and a manipulator arm for grasping and object interaction. Teaching them simultaneously typically creates competing gradients that confuse the learning process.
The framework tackles this through hierarchical decoupling, which treats the base and arm as separate learning problems with a one-way information flow from base to arm. This architectural choice mirrors how these robots are actually built, allowing the system to refine each component's behavior without the two subsystems fighting for control during training.
The system also uses what the researchers call a "policy-agnostic residual" approach. Rather than retraining an entire control policy from scratch, HiRe-MoMa keeps the robot's existing base policy frozen and only learns small corrective adjustments on top of it. This conservative strategy dramatically reduces the amount of real-world data needed to improve performance.
The Human-in-the-Loop Efficiency Gain

Perhaps most importantly for practical deployment, HiRe-MoMa achieves its gains with remarkably sparse human guidance. The framework uses a technique called Expert-Guided Value Alignment, which allows human interventions covering less than 20 percent of the training process to reshape how the learning algorithm evaluates success. By strategically placing human corrections at key decision points, the system can guide the robot's autonomous exploration far more efficiently than systems requiring constant supervision.
This matters because human time remains expensive and difficult to scale. A system that extracts maximum value from minimal oversight represents a meaningful step toward practical robot deployment in cost-sensitive environments.
Real-World Validation on Industrial Platforms
The researchers validated their approach on TIAGo++, a real mobile manipulator platform, rather than relying solely on simulation. This grounding in actual hardware is crucial for claims about real-world applicability. The experiments demonstrated that HiRe-MoMa consistently improved task completion rates regardless of which base policy the robot started with, suggesting the method's versatility across different robotic platforms.
The work addresses a critical gap in robotics research. While machine learning has advanced rapidly for perception and planning, translating those gains into physical systems that learn efficiently remains difficult. Most existing approaches either require extensive human demonstration or prohibitive amounts of trial-and-error on expensive hardware.
By combining architectural innovations with strategic use of sparse human feedback, HiRe-MoMa provides a practical pathway for deploying increasingly complex robotic systems without the training overhead that has historically limited real-world adoption.